
Microduck Playground


Reproducible reinforcement-learning experiments, policy demonstrations, and printable hardware add-ons for Pollen Robotics' Microduck.
This is an independent experimental continuation of
pollen-robotics/microduck_rl,
not an official Pollen Robotics release. For the initial public release, all
playground-specific work is consolidated into one commit on top of upstream
commit d424a0c,
preserving the original project history and attribution. Development after the
release uses ordinary commits. The upstream project can be added as a Git
remote when preparing focused contributions.
Experiments
Animated previews play directly in the table. Click one—or use its explicit full-video link—to open the complete silent MP4.
| Experiment | Preview | Result and artifacts |
|---|---|---|
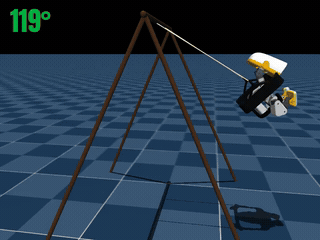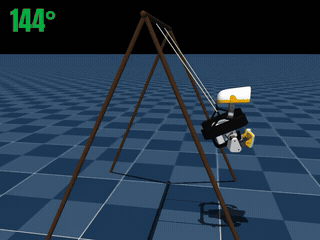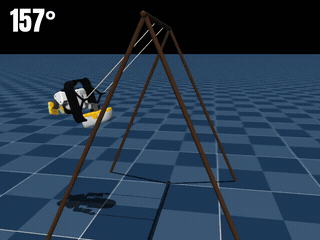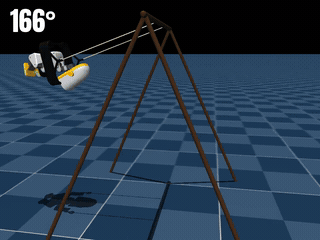
| Self-pumped swing |
|
Starts still and reaches a 173.20° strict full span. Full video · Experiment · Runtime adapter · ONNX on Hugging Face |
| Blind basketball balance | 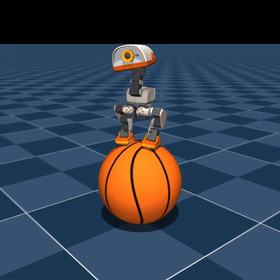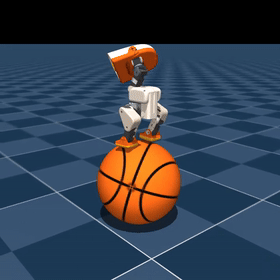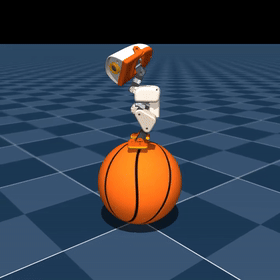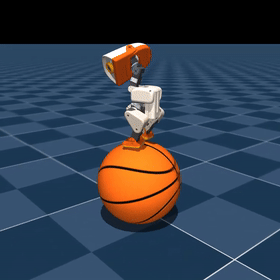 |
LSTM policy with no ball-state input: 97.01% survival over 60 seconds in 3,072 simulation trials. Experimental hardware-test candidate; hardware untested. Full video · Experiment and training · ONNX and checkpoint · LSTM runtime PR |
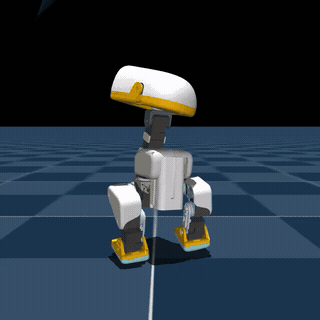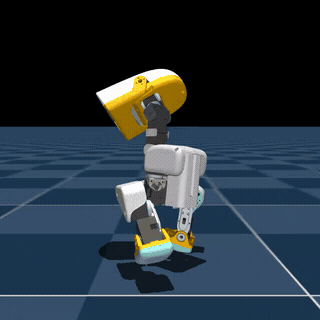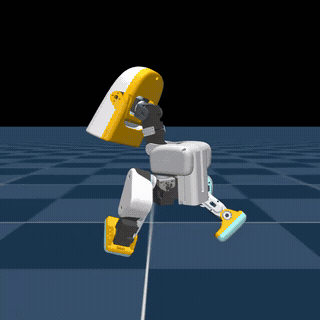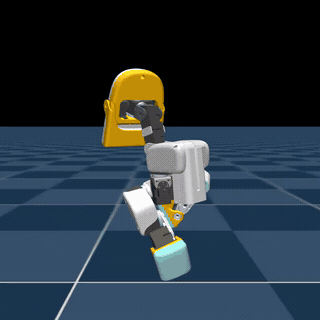
| Fast running |
|
Robustified iteration-12,195 simulation candidate: 1.651 m/s nominal,
and 1.612 m/s under backlash plus disturbance stress. Full video · Experiment · ONNX on Hugging Face |
| Stilt walking |
|
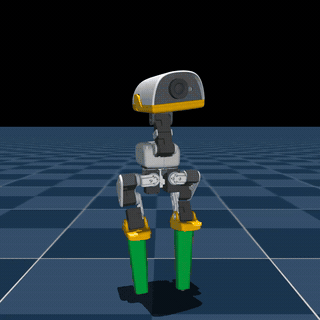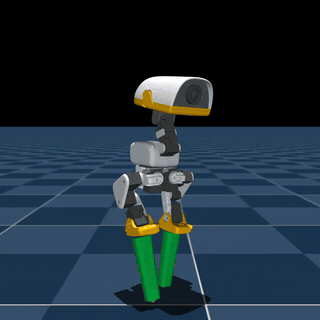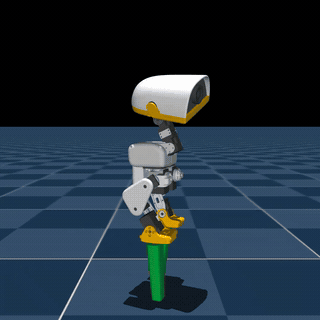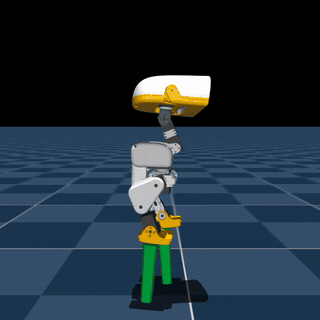
Blend-0.50 policies for 10, 15, 20, 25, and 50 cm, plus
1.0, 1.4, and 2.0 m simulation stilts (10 cm shown). Full video · Experiment · Hardware · Policies and videos |
| Climbing | 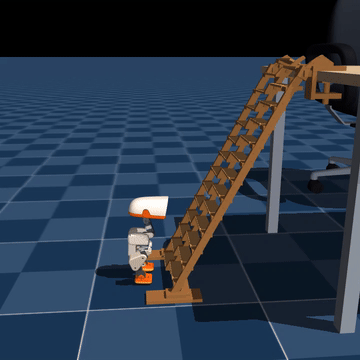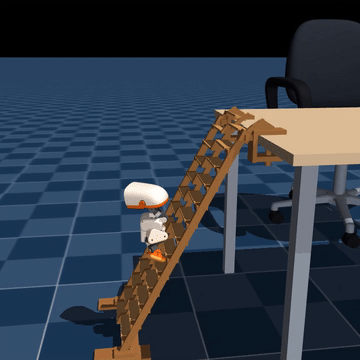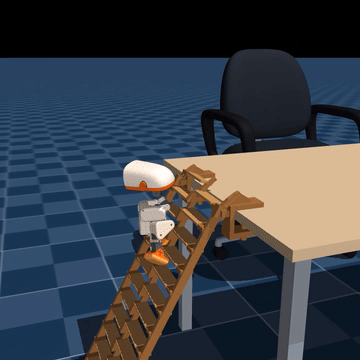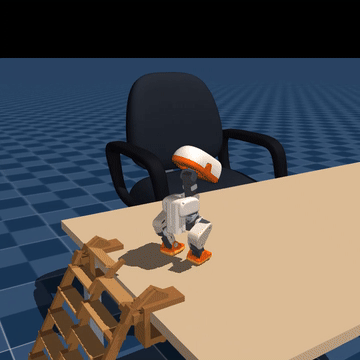 |
Climb, land, recover. Experiment and training · Ladder and mounts · Models |
| Chimney climbing |
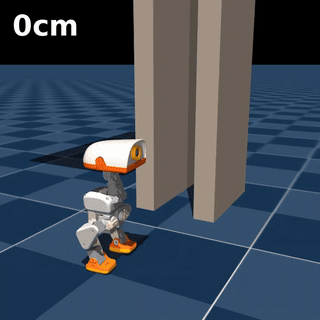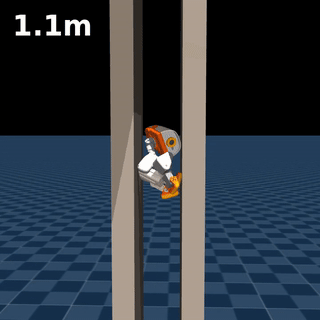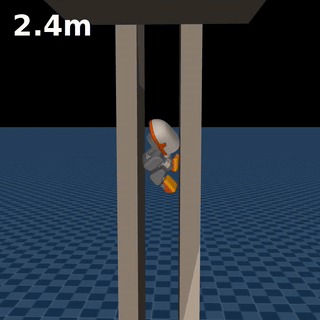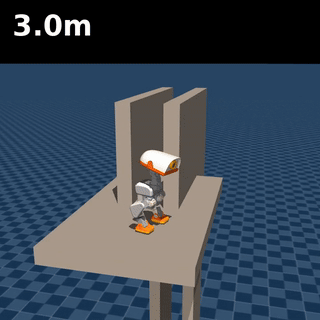
|
Braced climbing through a 12.5 cm gap to a 3 m platform.
Selected simulation rollout; hardware untested. Full video · Experiment and training · Climb, enter and exit policies |
| Raised-platform long jump | 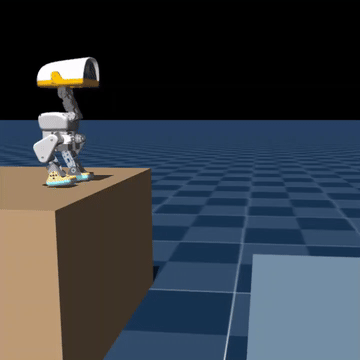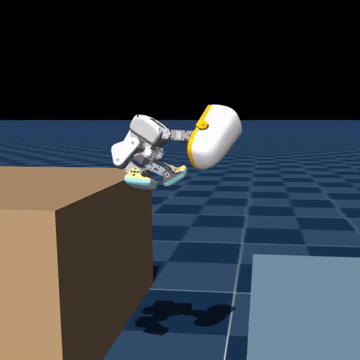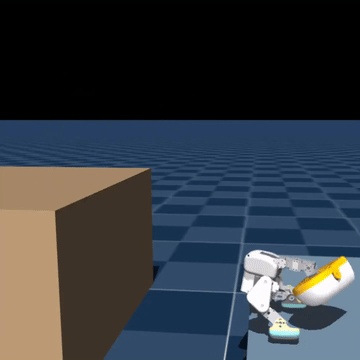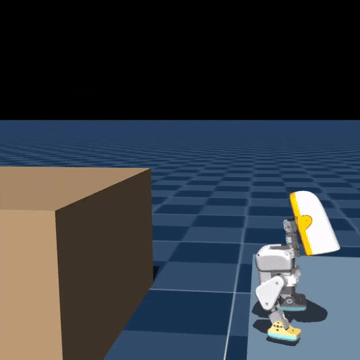 | Simulation only; not yet validated on hardware. Details and reproduction · Policy and training checkpoint |
| Raised-platform backflip | 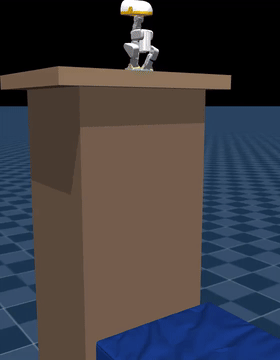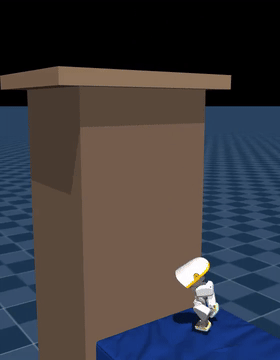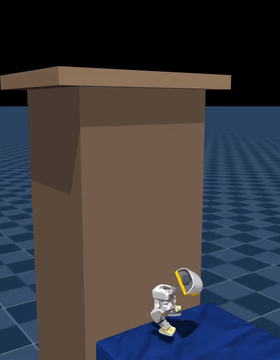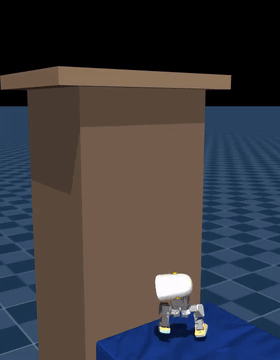 | Experimental simulation policy; hardware unvalidated. ⚠️ Landings may break the robot. Details and reproduction · Policy and training checkpoint |
Previews illustrate simulation behaviors. The jump/backflip excerpts are selected research footage; see their documented fresh-checkpoint verification and original footage provenance limits. Compact machine-readable evaluation records live beside each experiment.
Hardware galleries
The retained swing seat keeps the battery centered without occupying the
head-and-leg pumping corridors. It includes compliant locating pads, a padded
strap, and a removable buckle. The source generators, printable millimetre
meshes, MuJoCo collision hulls, and clearance reports are under
hardware/swing-seat.
 Front |
 Three-quarter |
 Side |
The stilt system replaces the removable soles and preserves explicit tip
contact geometry. The gallery uses the demonstrated green 10 cm blend-0.50
configuration. Parametric generators and printable meshes are under
hardware/stilts.
 Front |
 Three-quarter |
 Side |
 3D-printed prototype |
The modular climbing ladder has pin-free stacking joints, a central spine, a
matching floor base and printed tightening screws for the table mounts.
Printable models, generators, assembly instructions and the full gallery are under
hardware/ladder.
 Stacking joints |
 Floor base |
 Table mounts |
Quick start
A CUDA GPU and uv are recommended. Training
uses MuJoCo Warp through mjlab.
git clone https://github.com/Vottivott/microduck-playground
cd microduck-playground
uv sync

# Cheap configuration/training smoke test first.
uv run train Mjlab-SwingPump-MicroDuck \
  --env.scene.num-envs 64 \
  --agent.max-iterations 5

# Full swing training configuration.
uv run train Mjlab-SwingPump-MicroDuck \
  --env.scene.num-envs 4096
Repository layout
experiments/
  parkour/               raised-platform long jump and backflip
  basketball/            blind LSTM policy, evaluation, continuation guide
  running/               clean policy preview and result summary
  stilts/                policy index, executed curriculum, continuation guide
  swing/                 selected checkpoints, evaluation, media, methodology
hardware/
  stilts/                parametric stilt generator and printable meshes
  swing-seat/            retained-seat generator, meshes, clearance reports
src/mjlab_microduck/     tasks, robot models, actuator model, rewards
scripts/                 evaluation, export, rendering, and selection tools
integrations/            policy-specific deployment adapters
tests/                   CPU configuration and invariant tests
docs/                    supporting research and training notes
Scope and safety
These are simulation experiments, not hardware safety certifications. The swing model simulates two elastic tension-only cords and randomized actuator and sensor dynamics, but real cord knots, frame flex, textile contact, servo temperature, and assembly tolerances remain. Extreme-height stilts require an engineered load path and fall protection. Use a safety tether, current limits, an emergency stop, a clear exclusion zone, and conservative incremental tests.
Upstream and contributions
To compare against or prepare a focused pull request for Pollen's project:
git remote add upstream https://github.com/pollen-robotics/microduck_rl.git
git fetch upstream
License
Software is licensed under Apache-2.0; see LICENSE. As in the
upstream project, 3D hardware design files are licensed under Creative Commons
Attribution-NonCommercial-ShareAlike 4.0 International; see
LICENSE-HARDWARE. Third-party Microduck assets retain
their original attribution and terms. See NOTICE and the
hardware-specific READMEs.